by Enter Search · by Esc Close
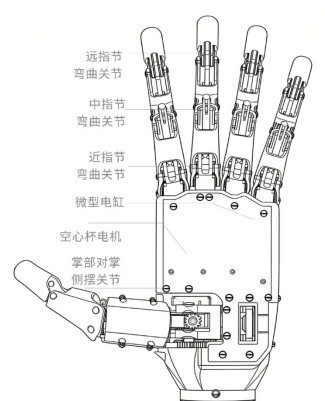
Robot dexterous hands contain bending joints across multiple finger phalanges and palm side-swing joints, largely driven by miniature hollow-cup motors and micro linear actuators. As the core sensing device, miniature Magnetic Absolute Encoders acquire the angle and linear displacement of every finger joint, enabling fine grasping, pinching, and manipulation — a key hardware foundation for human-like dexterous operation.
Extreme miniaturization constraints: the space inside finger joints is extremely tight, imposing strict demands on encoder IC, code disc, and magnet size; conventional encoders cannot be assembled.
Multi-channel synchronous feedback: with multiple fingers and joints moving simultaneously, multiple angle channels are needed / displacement signals acquired synchronously to ensure coordinated motion consistency.
Balancing accuracy and speed: hollow-cup motors run at high speed, requiring both high-speed support and small-angle detection accuracy for fine control.
Linear + Rotary hybrid detection: with both rotary joints and micro linear actuators, an angle encoder and linear encoder pair is needed
Mass-production cost pressure: dexterous hands have many channels, and per-set device cost directly affects the whole machine BOM cost.
For micro joints of dexterous hands, it provides rotary angle encoders + Complete micro absolute linear encoder kit:
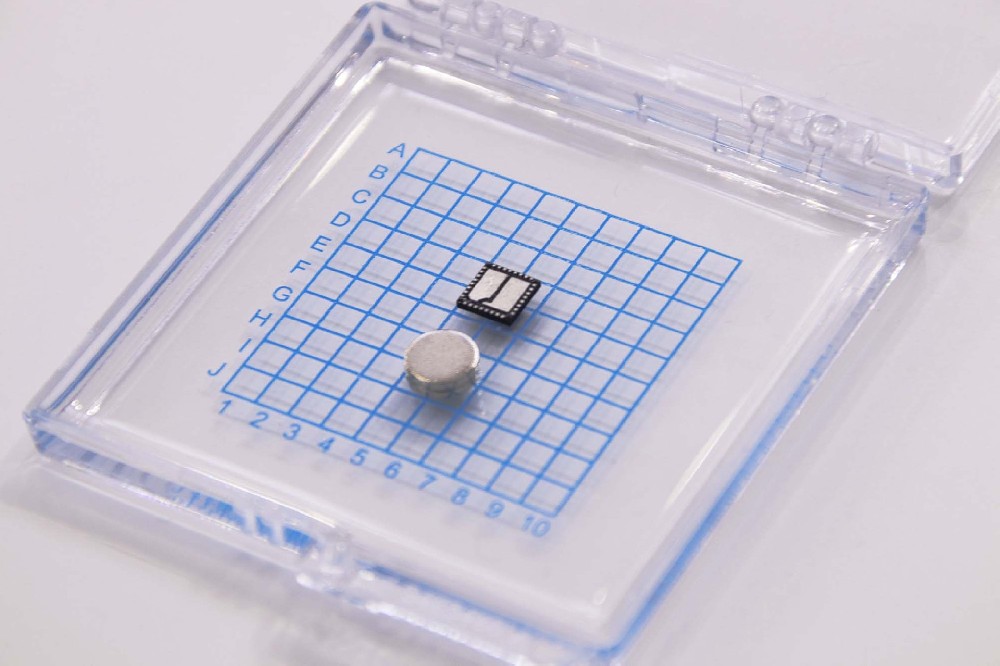
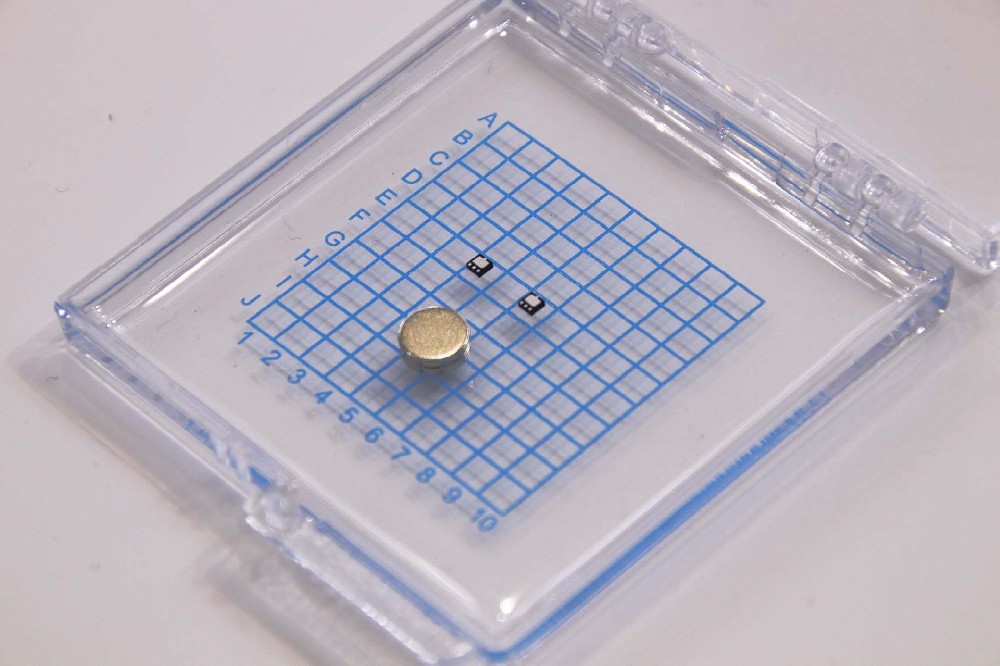
Rotary angle solution:EAS-D010KM-VS, EAS-D006ZT-VS, EAS-D006ZT-DS, suited to hollow-cup motors, delivered as a complete set with IC, magnet, and code disc; supporting analog Sin/Cos and digital ABZ/SPI and other outputs;
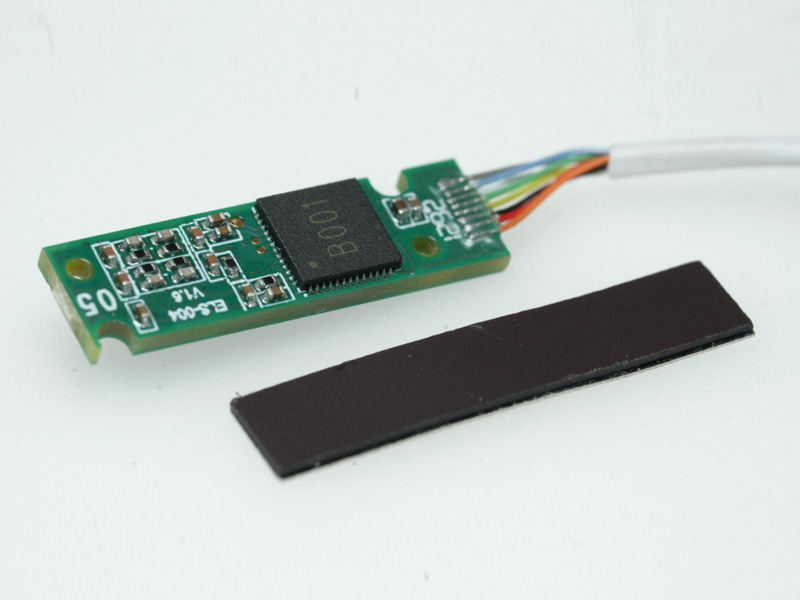
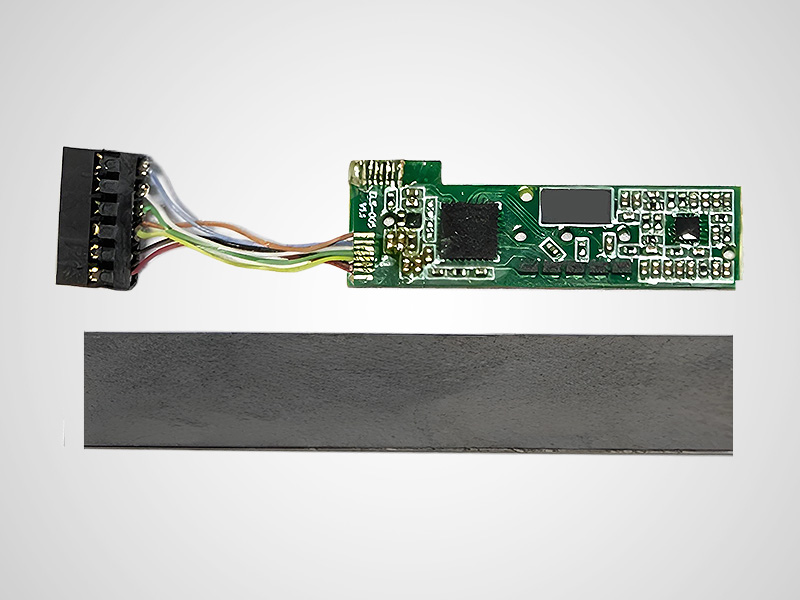
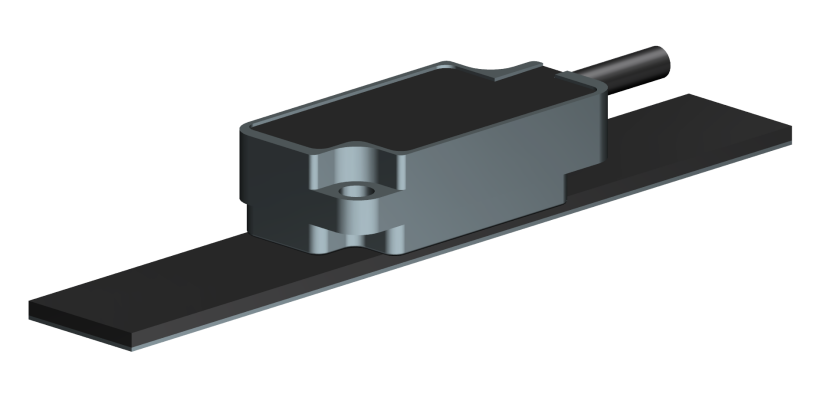
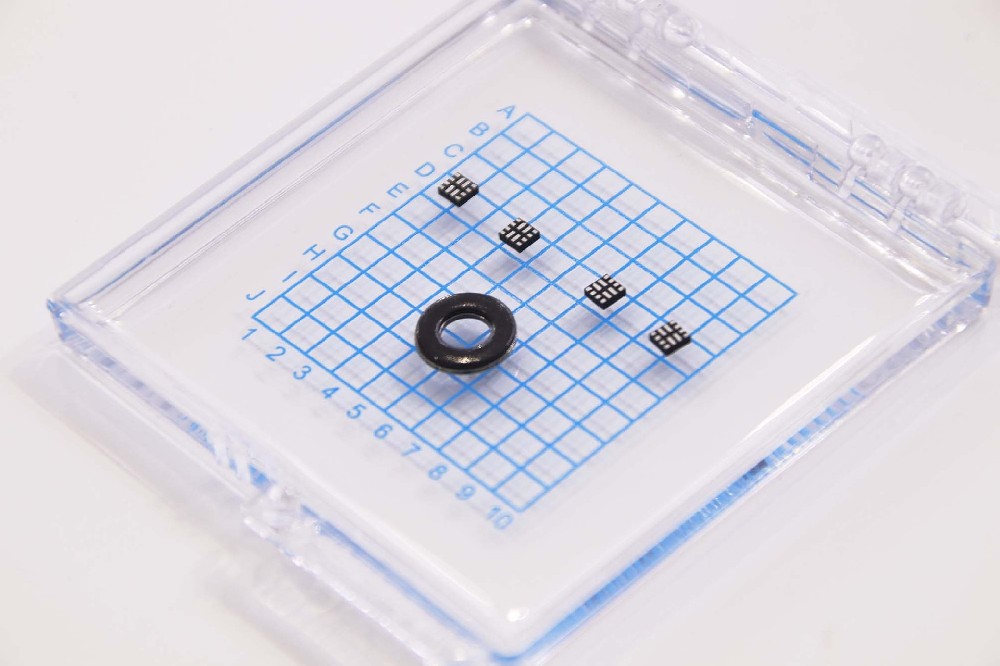
Linear displacement solution:ELS-004, an absolute linear encoder dedicated to micro linear actuators.
Complete material kit delivery, accessories PCB layout and mechanical mounting drawings suit integration into the cramped finger cavity, shortening dexterous hand development and debugging cycles.
✅ Ultra-small size adaptation: the smallest IC reaches 1.5×1.5mm, directly embedding into the cramped joint cavity of fingers and suiting the compact structure of hollow-cup motors.
✅ High-performance detection: the angle solution offers resolution up to 21-bit and repeatability up to 0.02°, supporting speeds above 100000 RPM; the linear solution ELS-004 delivers an effective resolution of 0.2 μm, meeting micro-displacement detection needs.
✅ Rich output interfaces: analog Sin/Cos, digital SPI, ABZ, UVW outputs to choose from, suiting different driver control boards.
✅ Complete multi-form solution: simultaneously covering rotary joint angle detection and micro linear actuator displacement detection, one-stop meeting the mixed-motion detection needs of dexterous hands.
✅ Domestic IDM, full chain self-controlled: in-house TMR/xMR sensing ICs, complete material supply, cost advantage for multi-joint batch applications, and support for custom development.