by Enter Search · by Esc Close
The angle encoder is the core sensing unit in the servo closed loop of robot joints, outputting joint angle and speed signals in real time and directly determining robot positioning accuracy, motion stability, and human-robot collaboration safety.
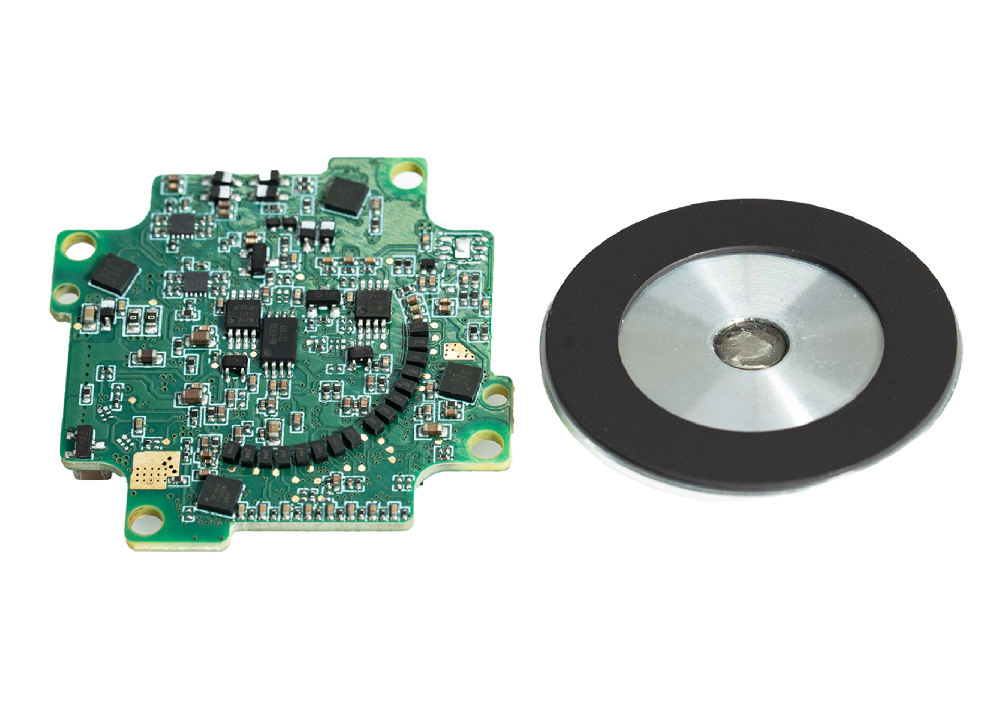
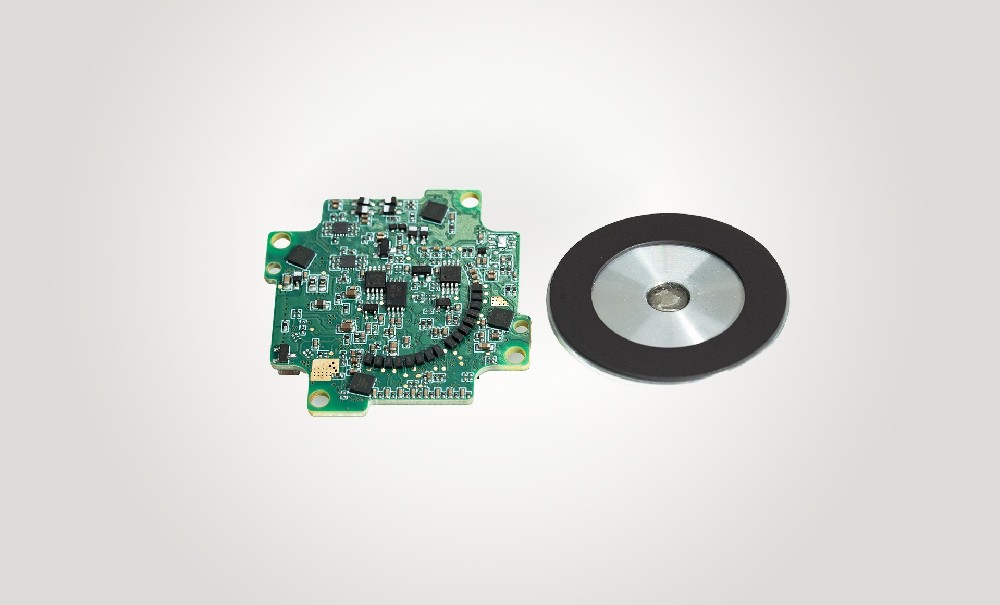
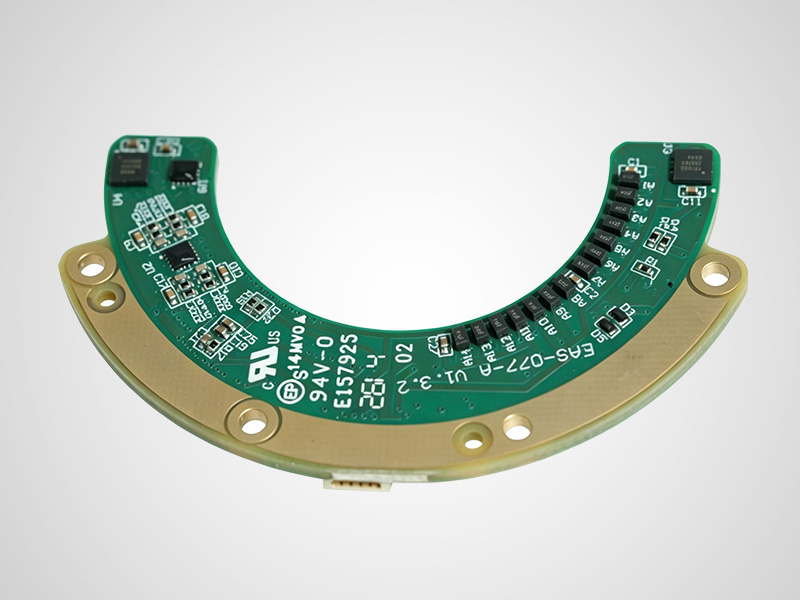
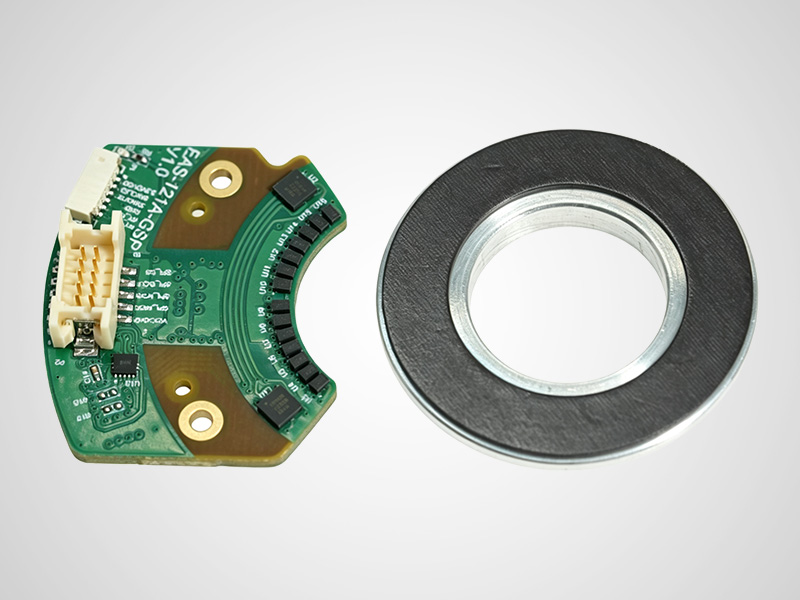
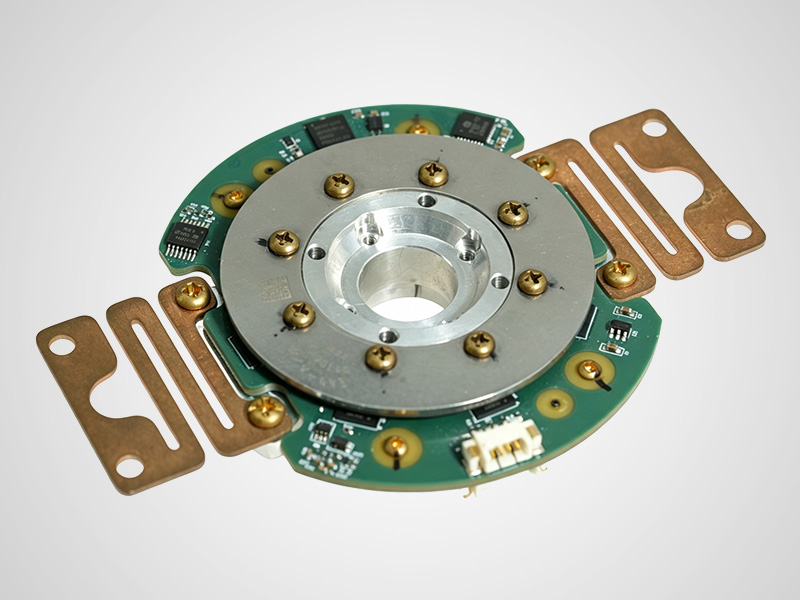
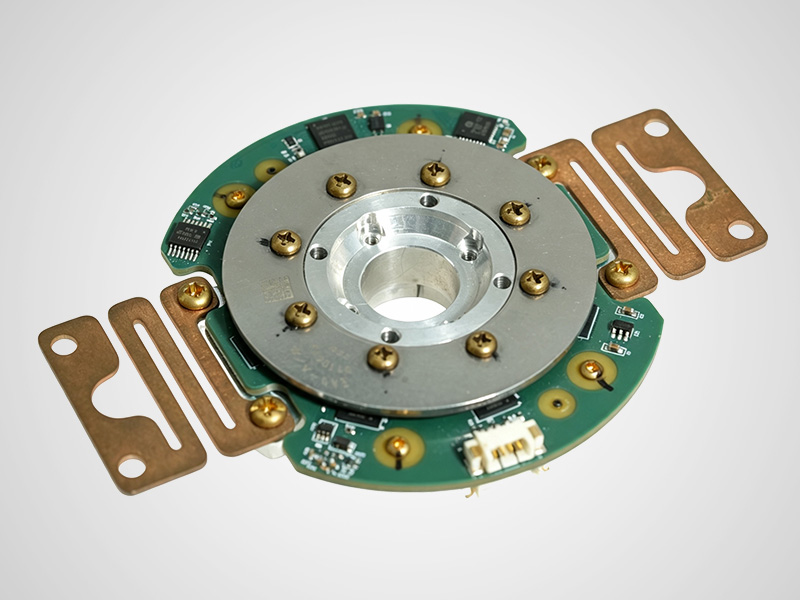
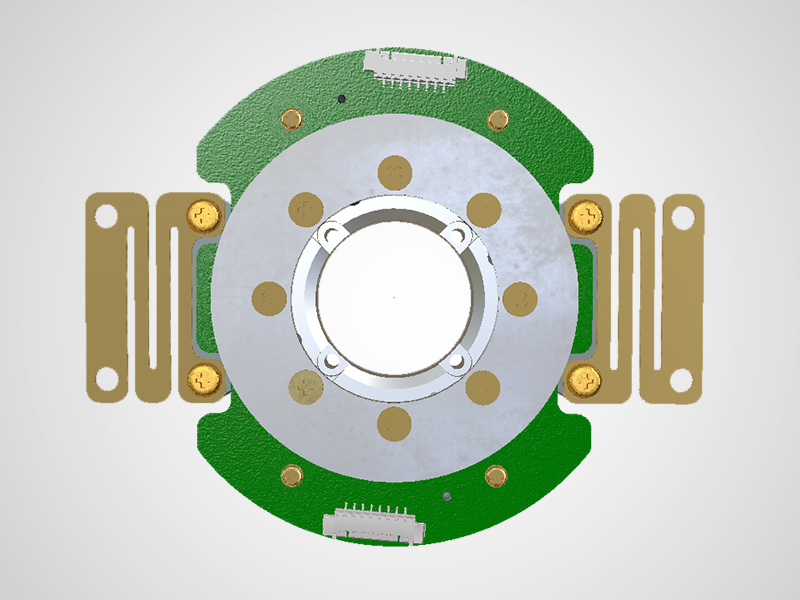
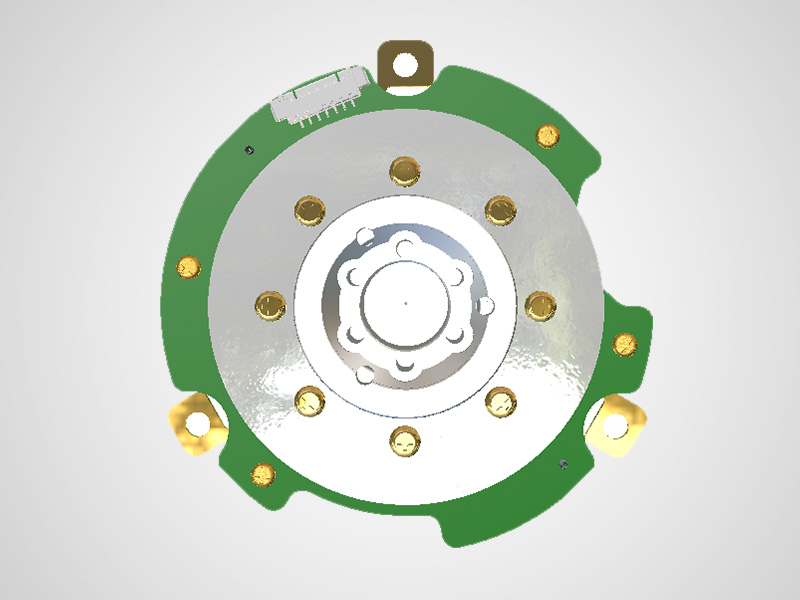
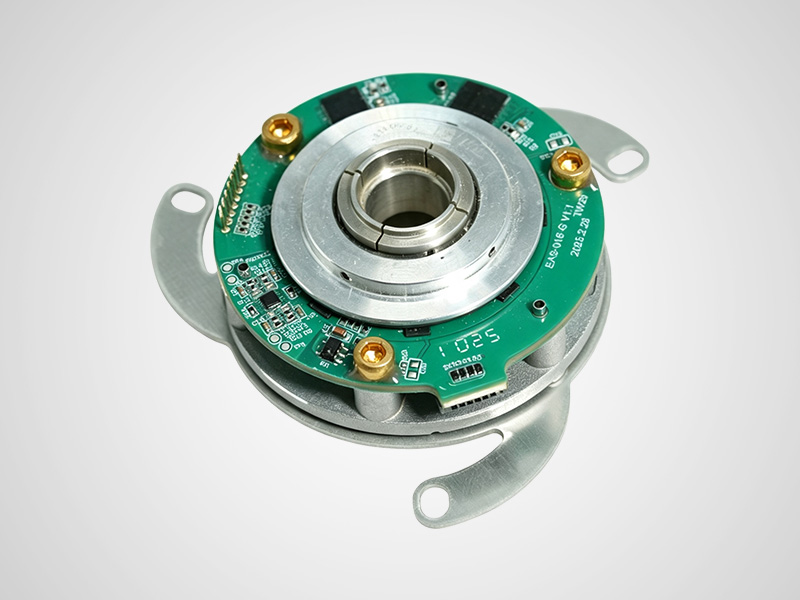
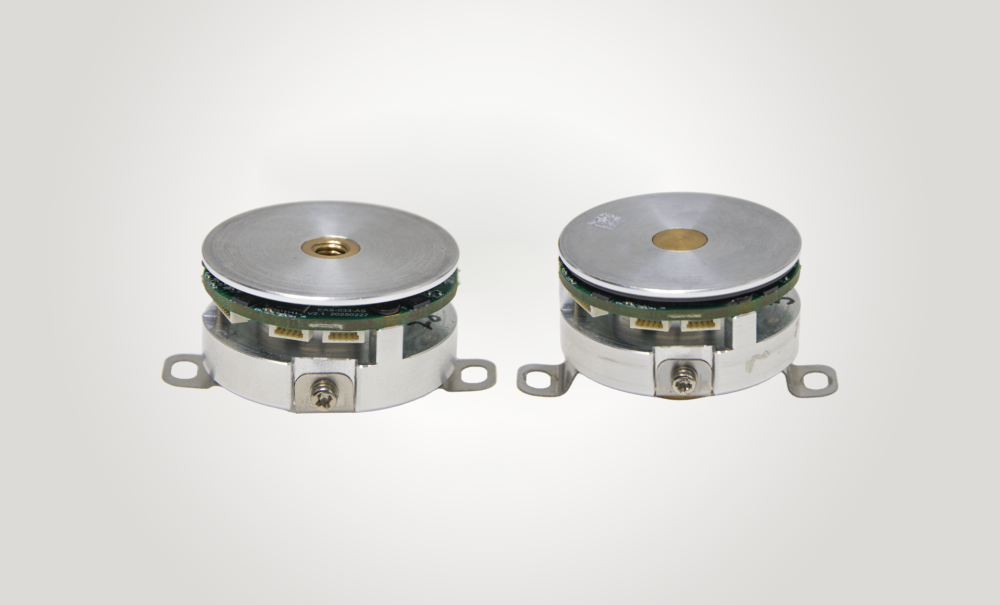
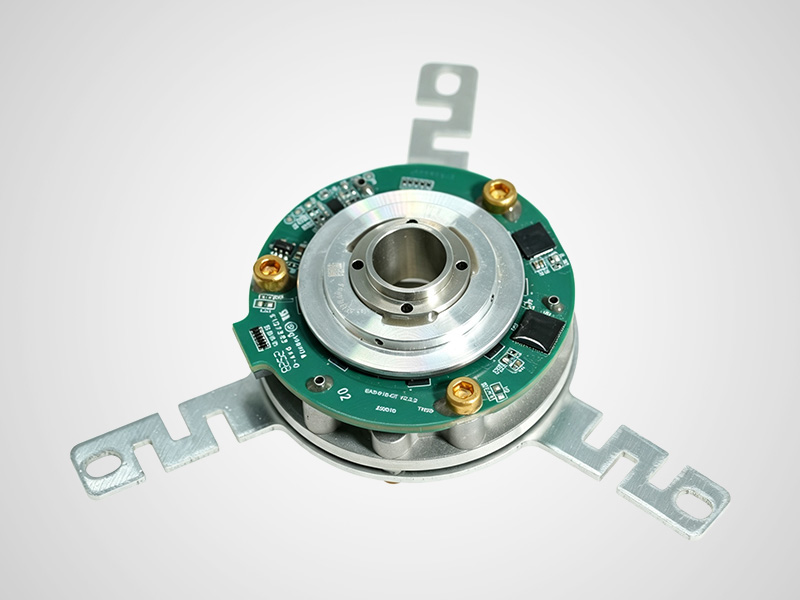
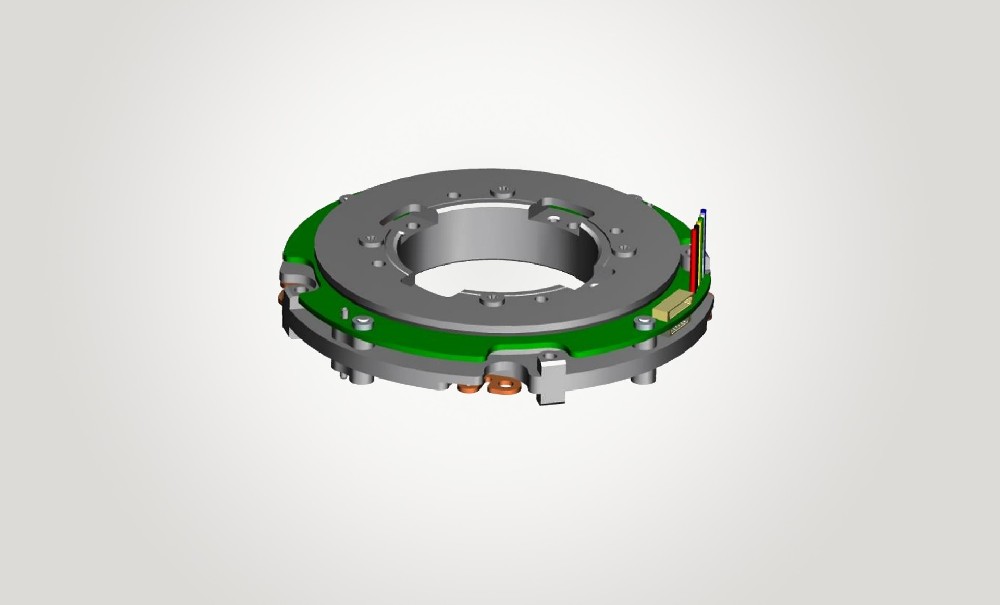
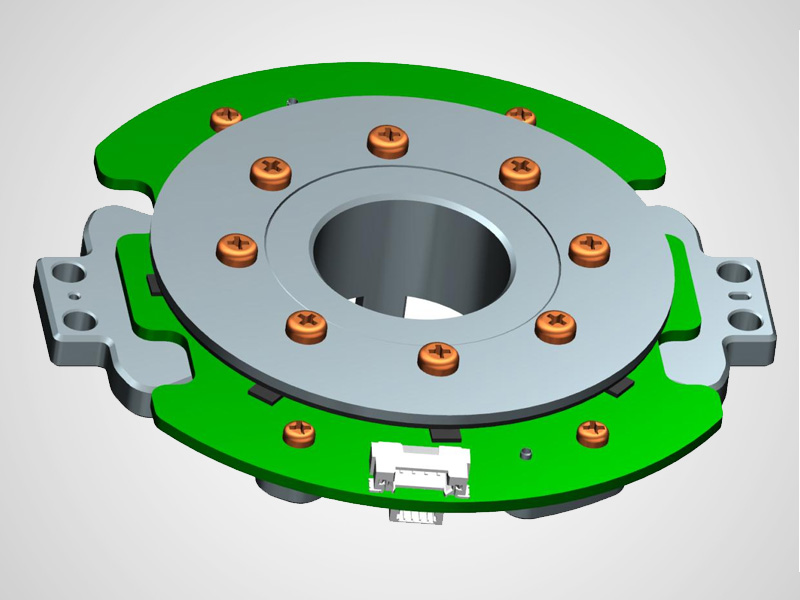
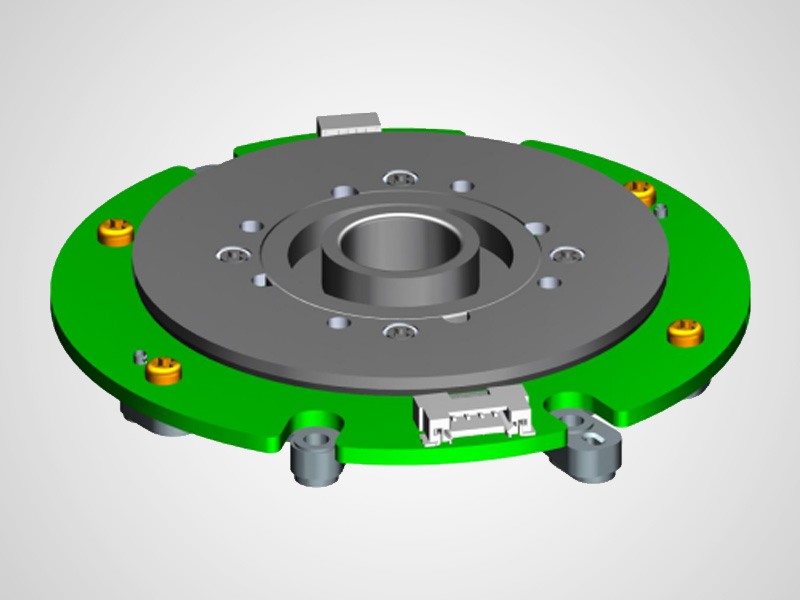
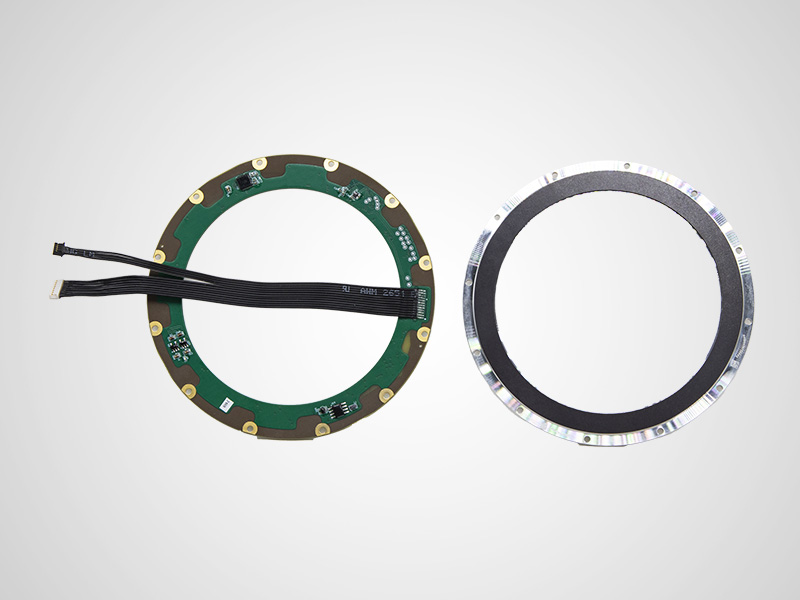
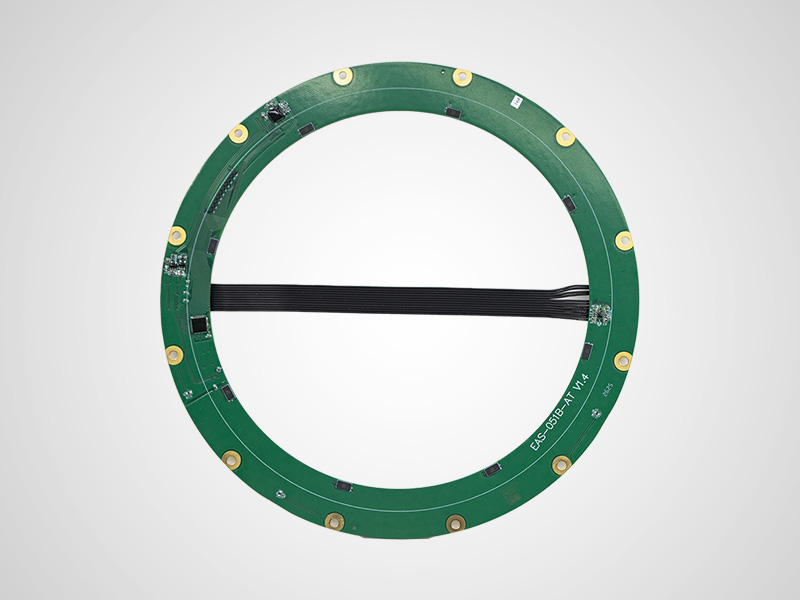
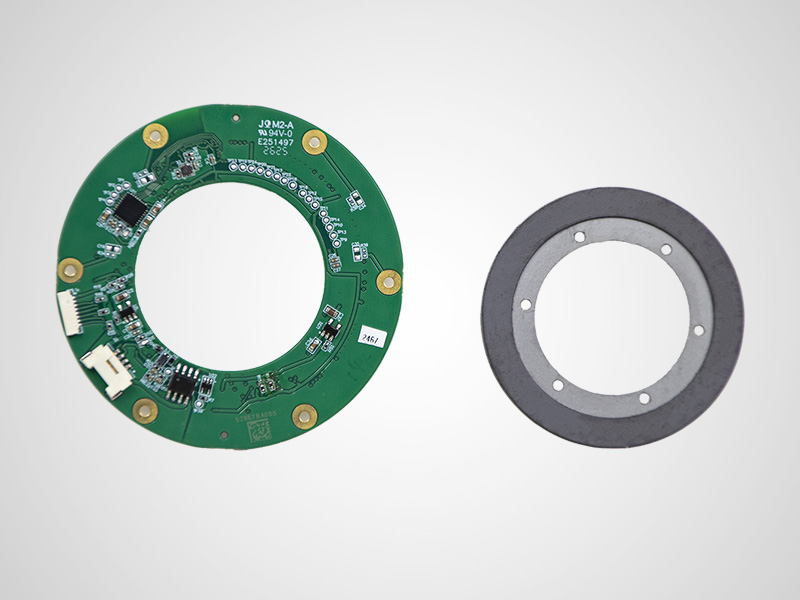
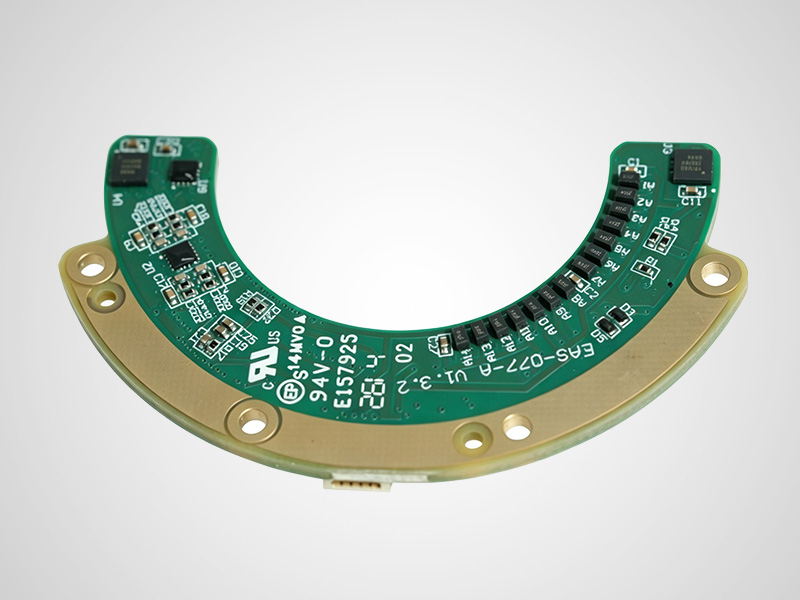
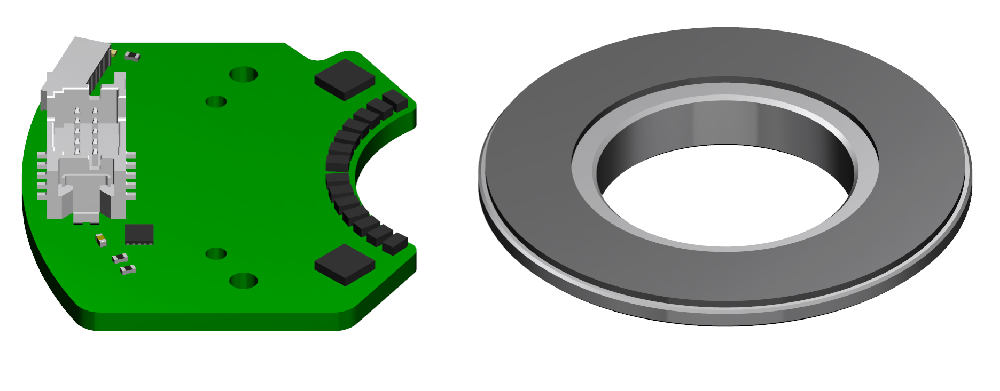
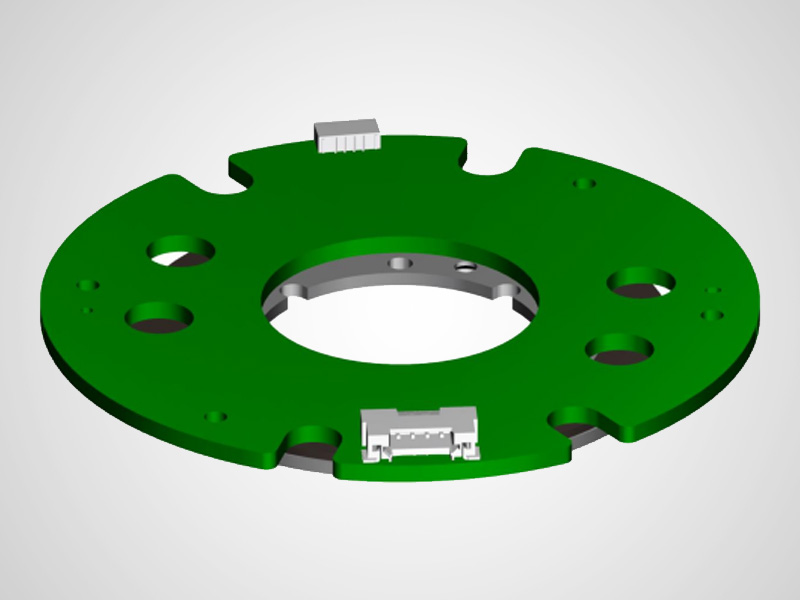
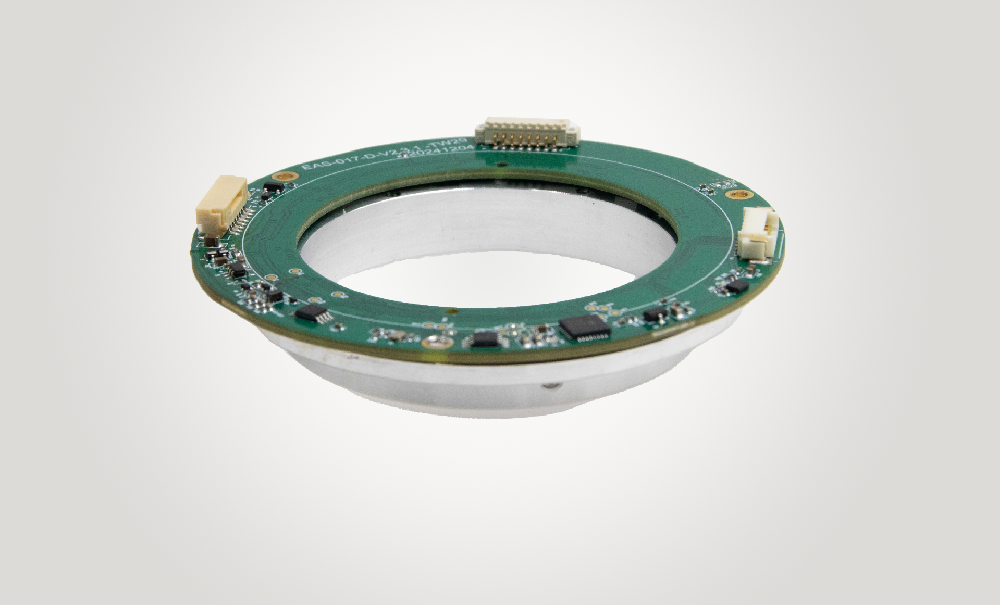
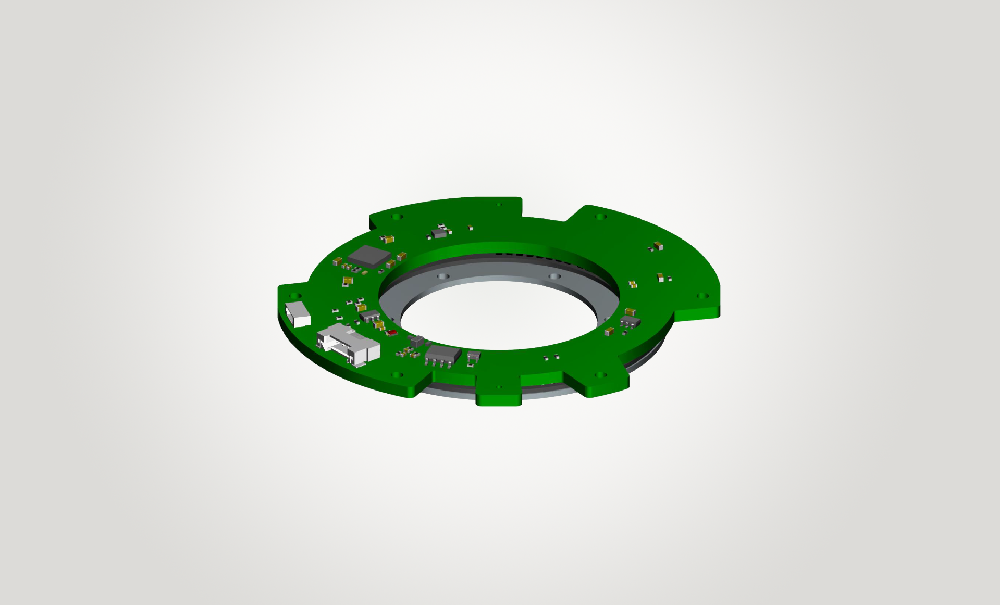
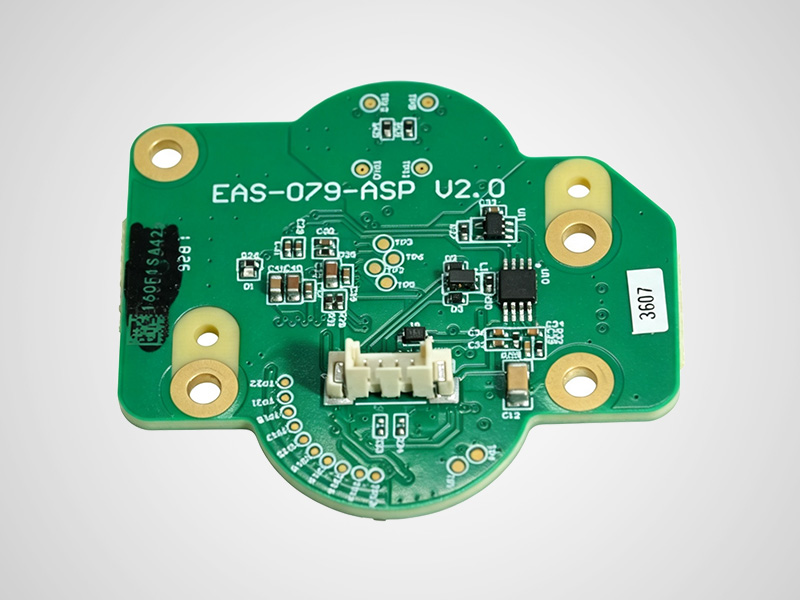
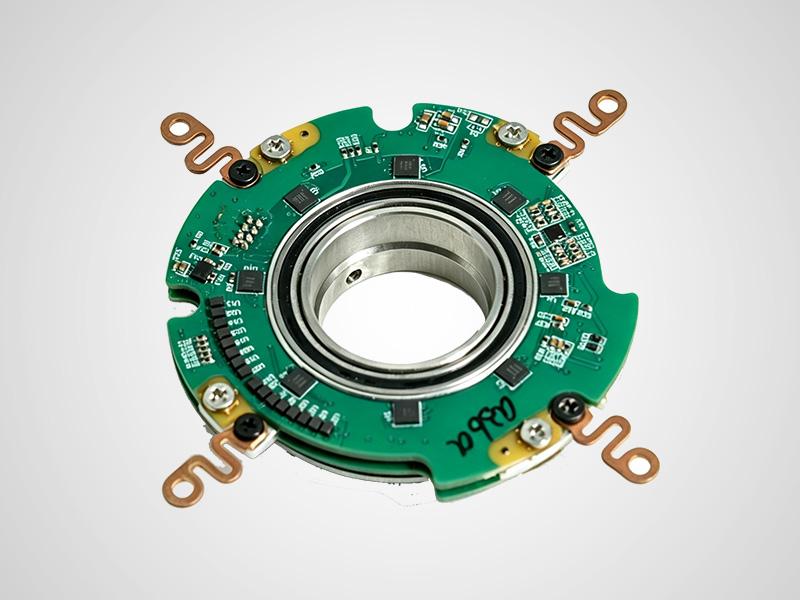
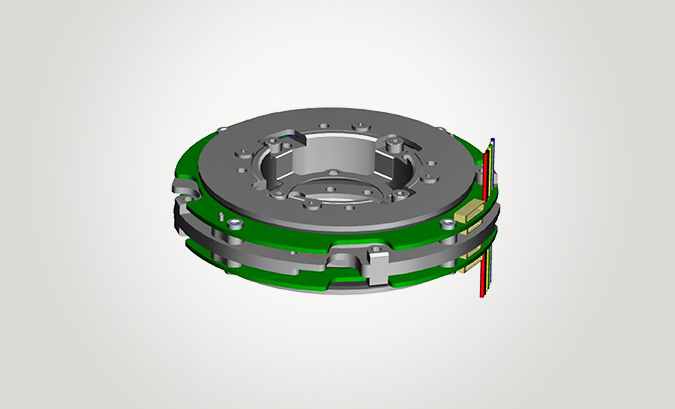
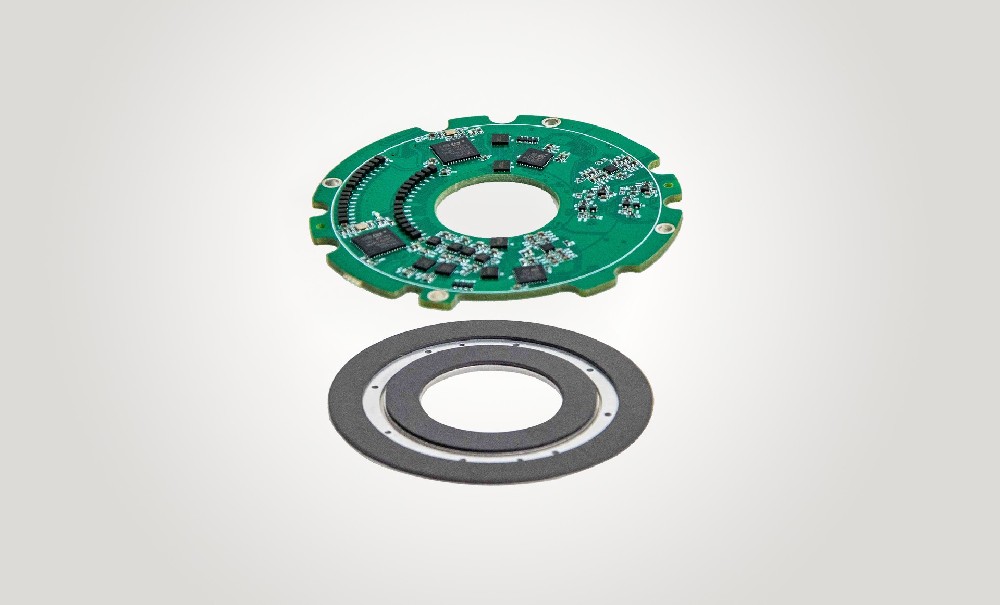
With vibration and shock resistance, a thin and light structure, and large hollow bore, Magnetic Encoders are widely suited to collaborative robots and industrial robotic arm joints, supporting high-precision robot development.
- Compact internal joint space imposes strict demands on encoder miniaturization and hollow integration
- Vibration and temperature cycling easily cause accuracy drift; human-robot collaboration scenarios require functional safety redundancy
- High resolution and high repeatability requirements, with some applications needing battery-backed multi-turn absolute position detection
- Imported devices have long lead times and high cost, while needing compatibility with RS485, SPI, BiSS-C, and other servo communications
✅ Full product matrix
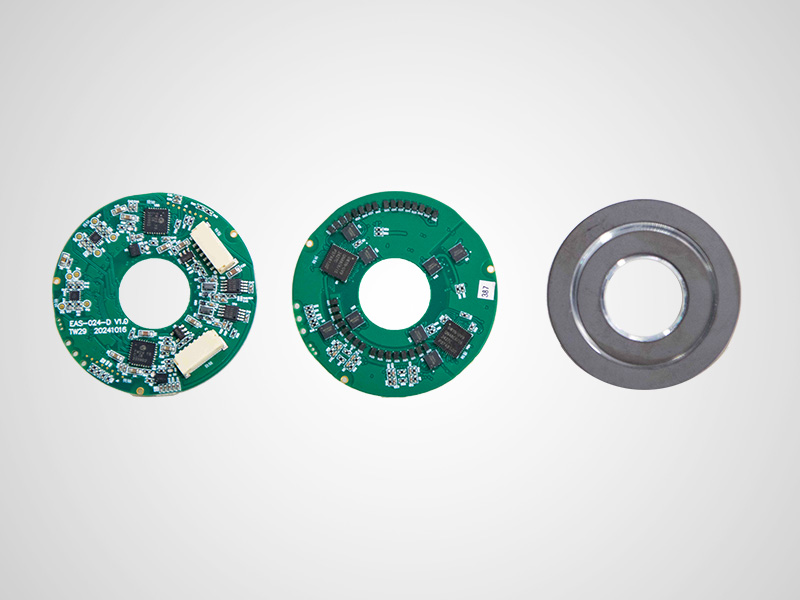
Covers functional safety dual-redundant, integrated hollow-shaft, split, and battery-backed multi-turn absolute encoders;23-26 bit resolution, repeatability up to 0.001°, suiting selection across different joint structures.
✅ High stability under harsh working conditions
Based onxMR (AMR/GMR/TMR) magnetoresistive core technology, shock and vibration resistant, with minimal lifetime accuracy drift; dual-encoder redundant design meets the functional safety needs of industrial collaborative robots.
✅ High-speed real-time signal output
SupportsRS485 / SPI / BiSS-C mainstream protocols, 30 kHz high control frequency, data update latency <2 μs, and small speed fluctuation during high-speed motion.
✅ Full-chain self-controlled IDM
In-house wafer and code disc manufacturing, IC- Full in-house chain from IC to module, delivered as a complete encoder kit, balancing mass production with fast customization for continuous cost reduction.