by Enter Search · by Esc Close
During running, jumping, and obstacle crossing, quadruped robot joints undergo high-frequency impact and severe vibration; as the core joint position feedback device, the encoder directly determines gait stability and motion reliability.
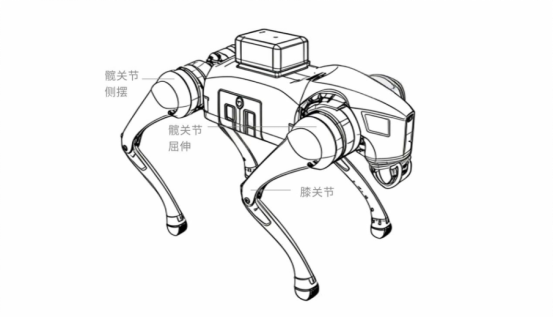
- Strong impact vibration on landing easily causes angle signal jitter
- Compact internal joint space imposes strict demands on device size
- Needs to read multi-turn angle directly at power-on, suiting complex gait control
- Mass production imposes high demands on assembly compatibility and cost control
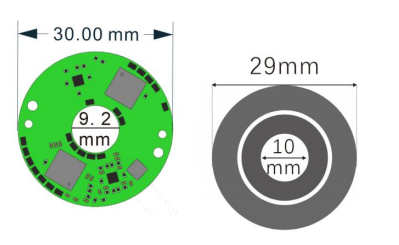
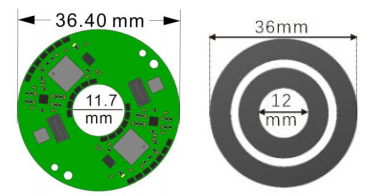
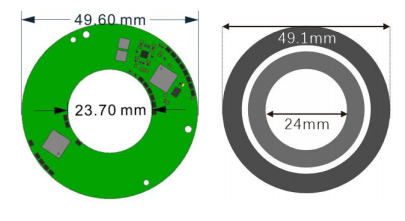
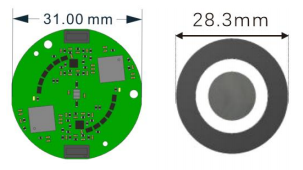
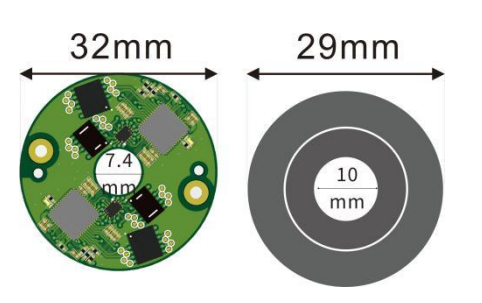
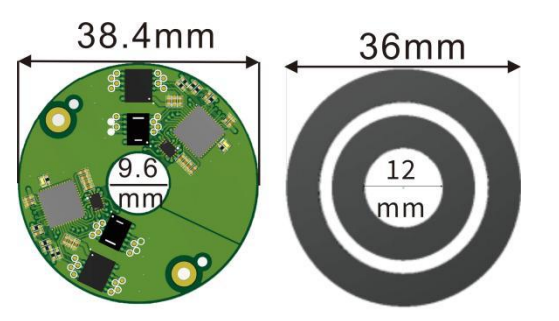
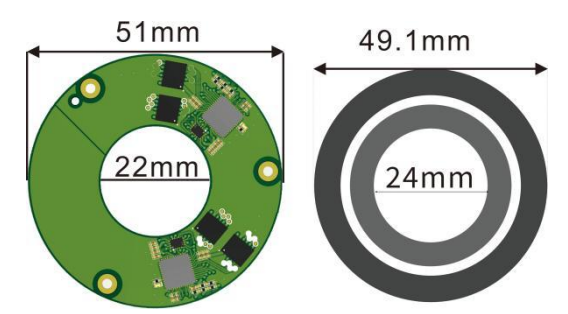
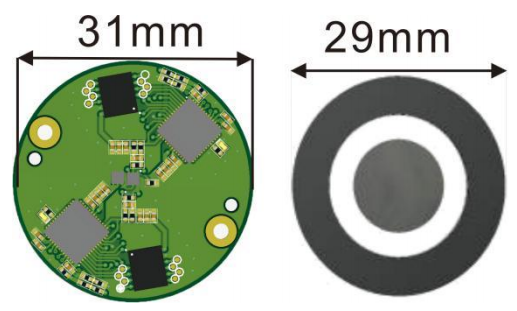
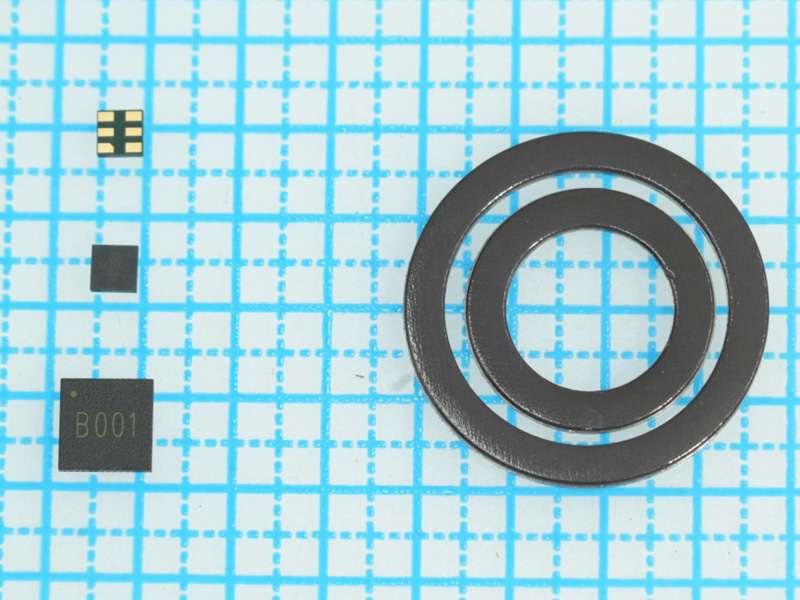
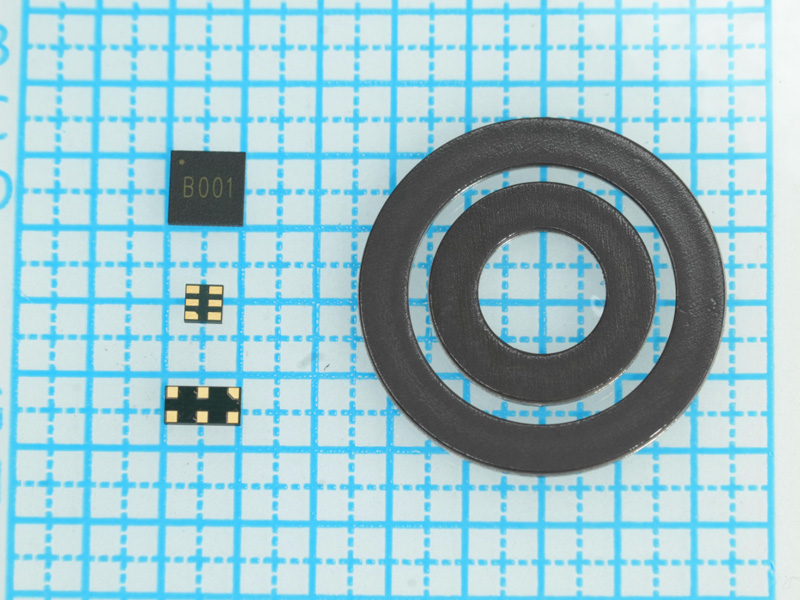
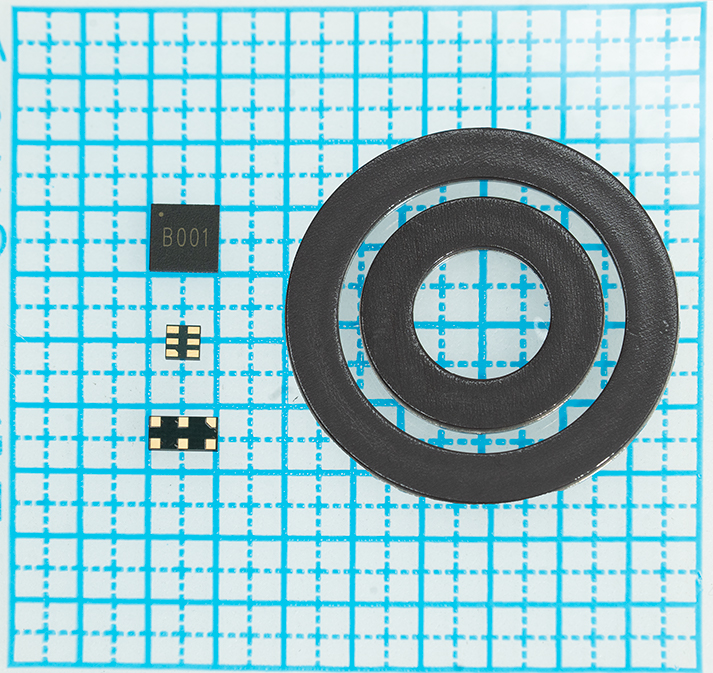
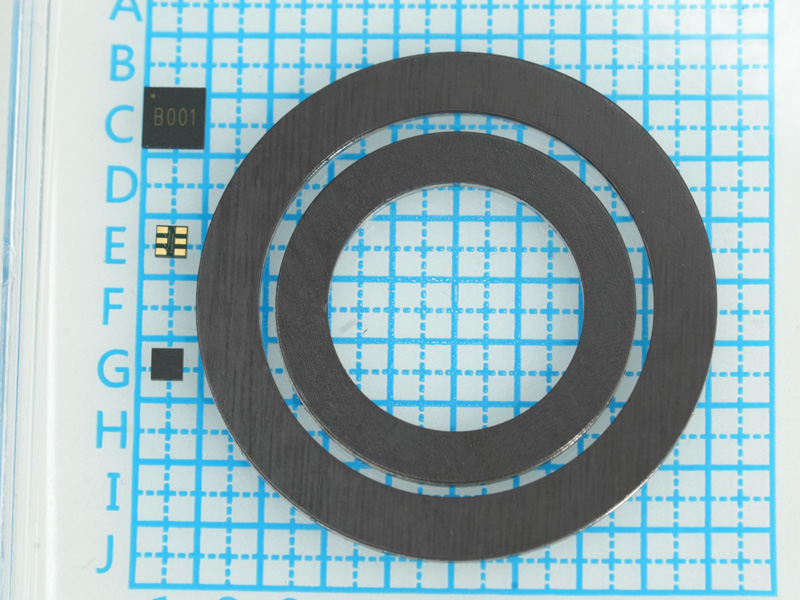
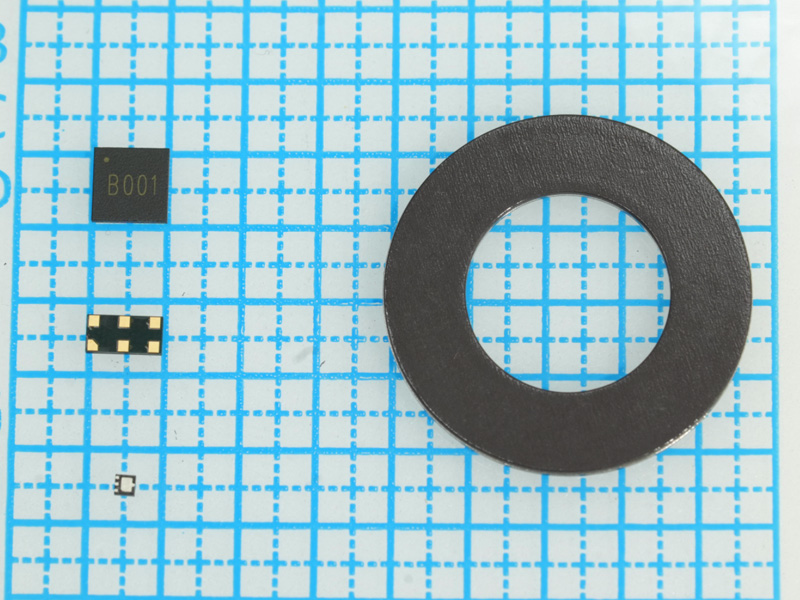
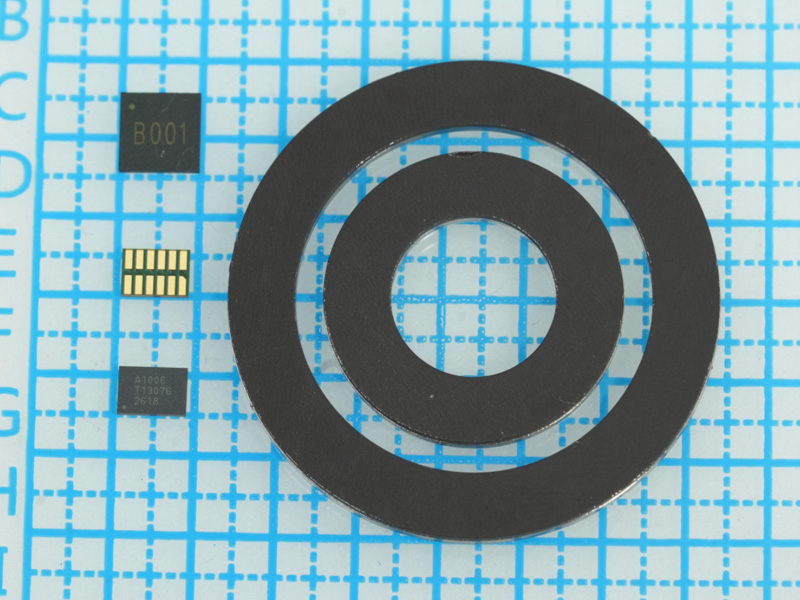
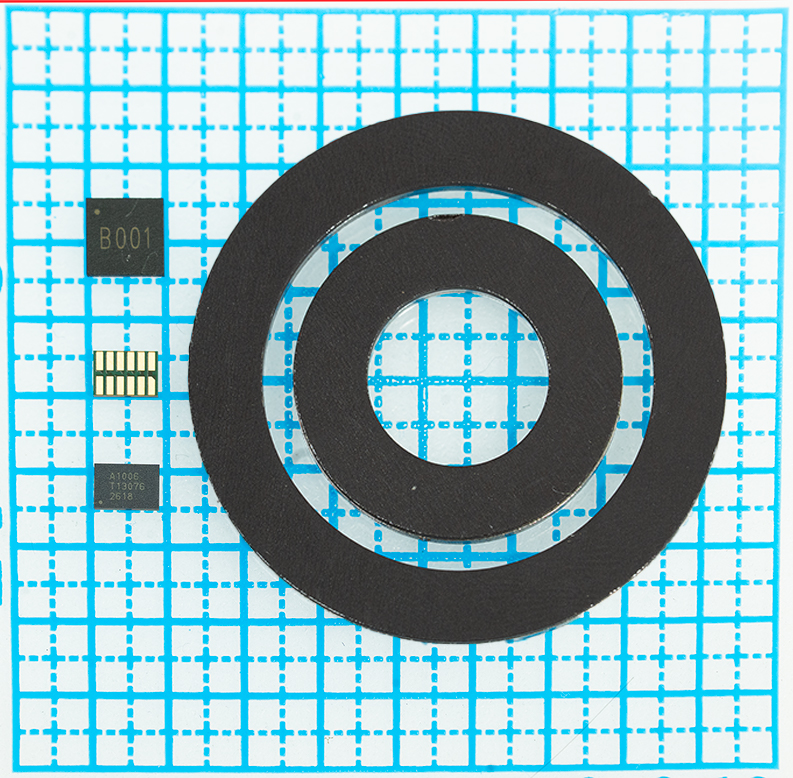
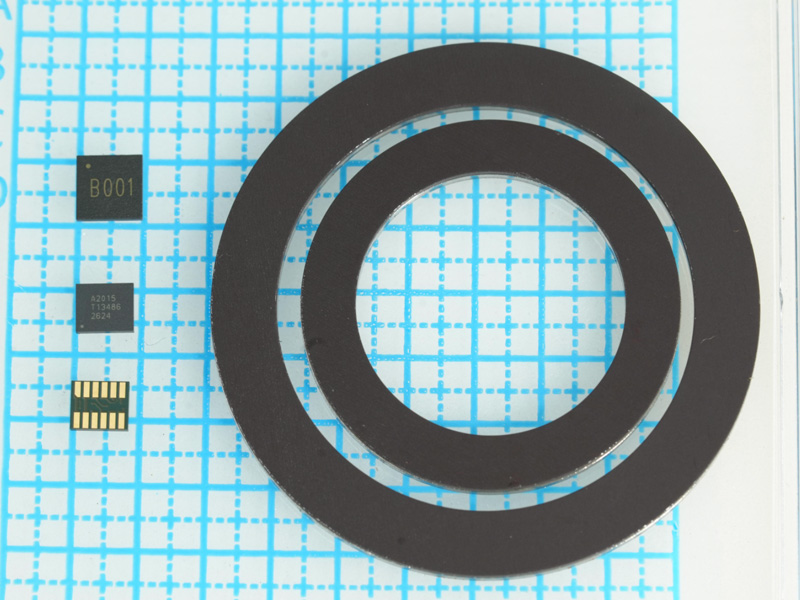
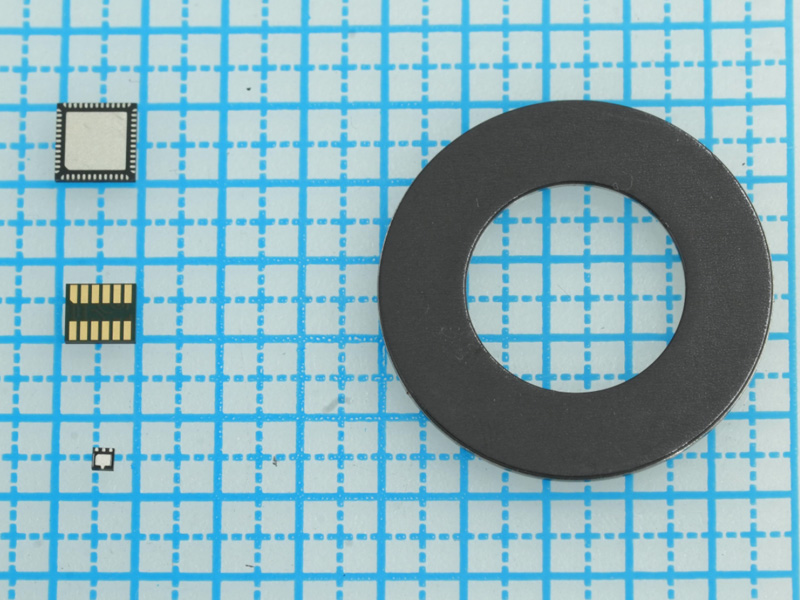
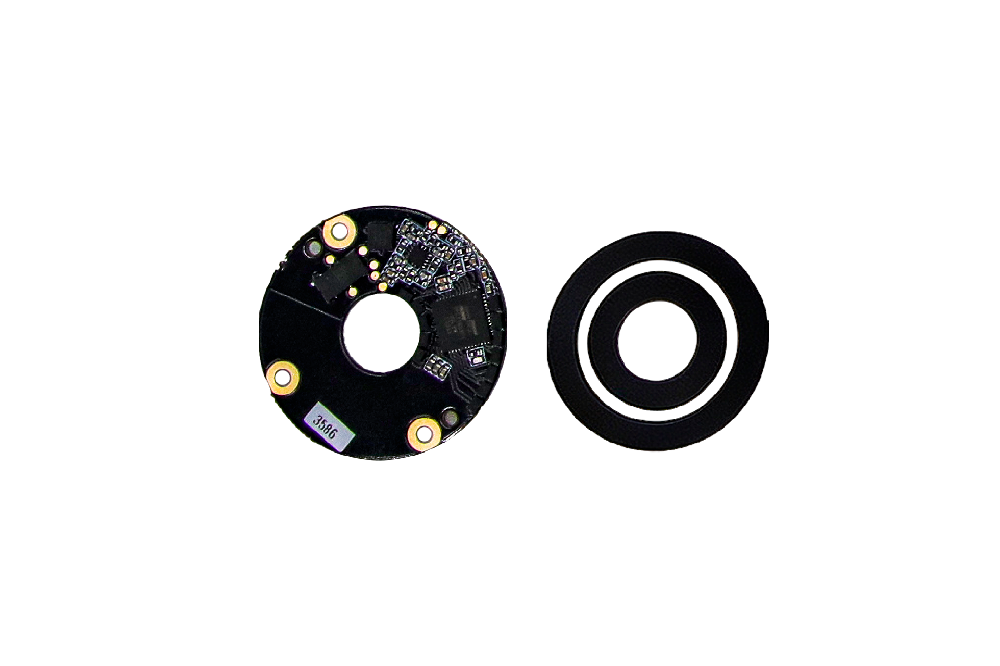
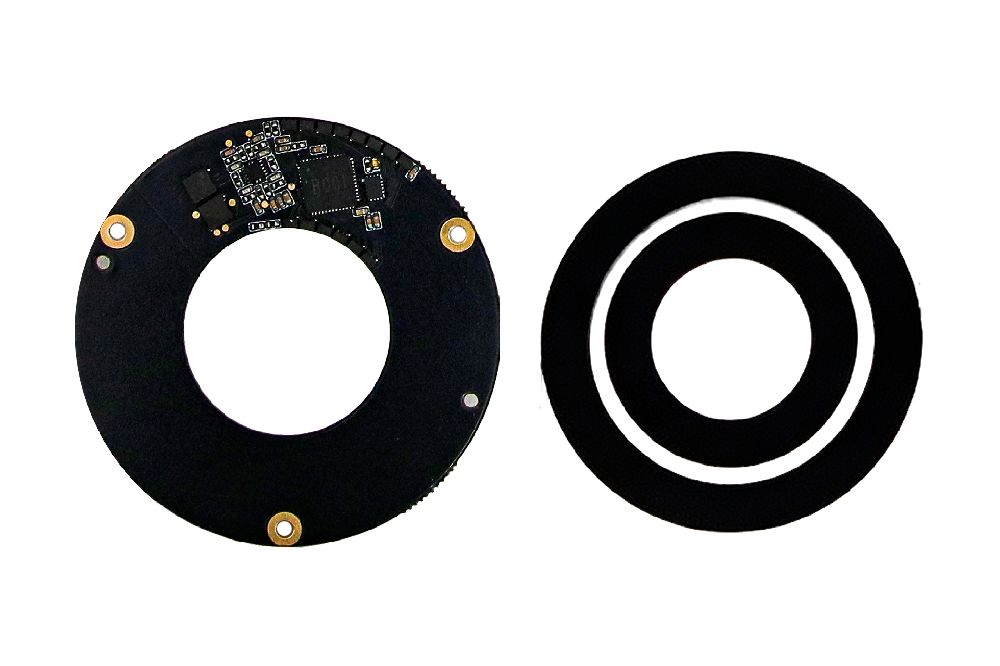
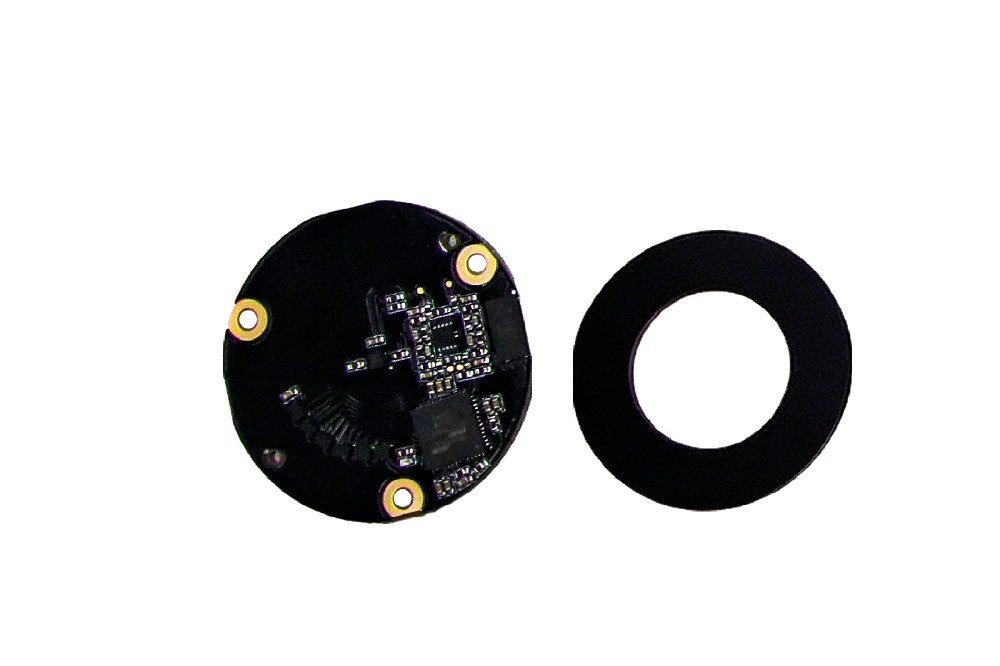
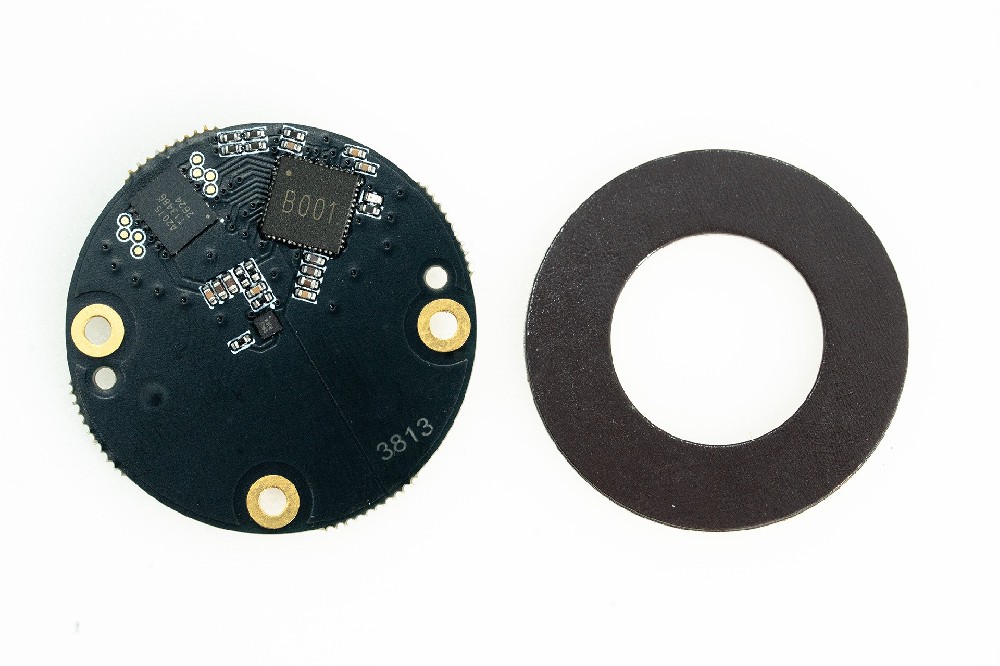
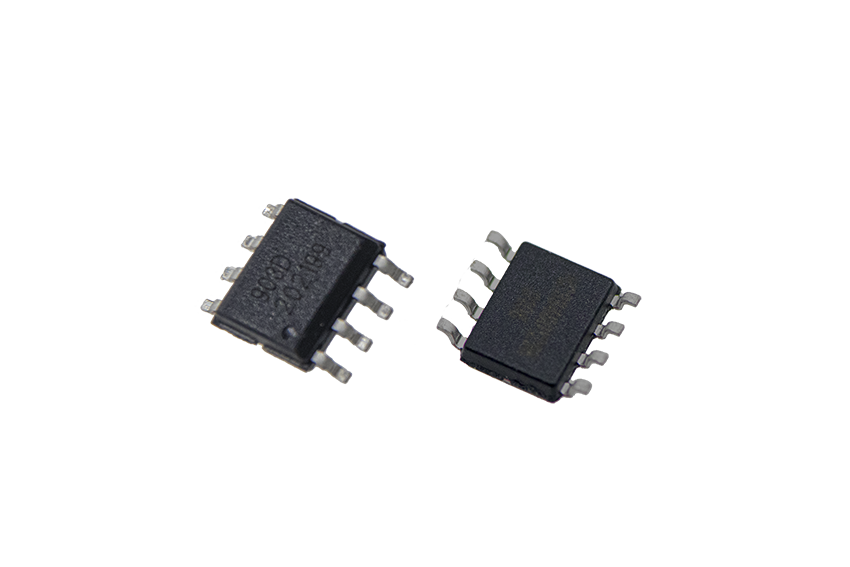
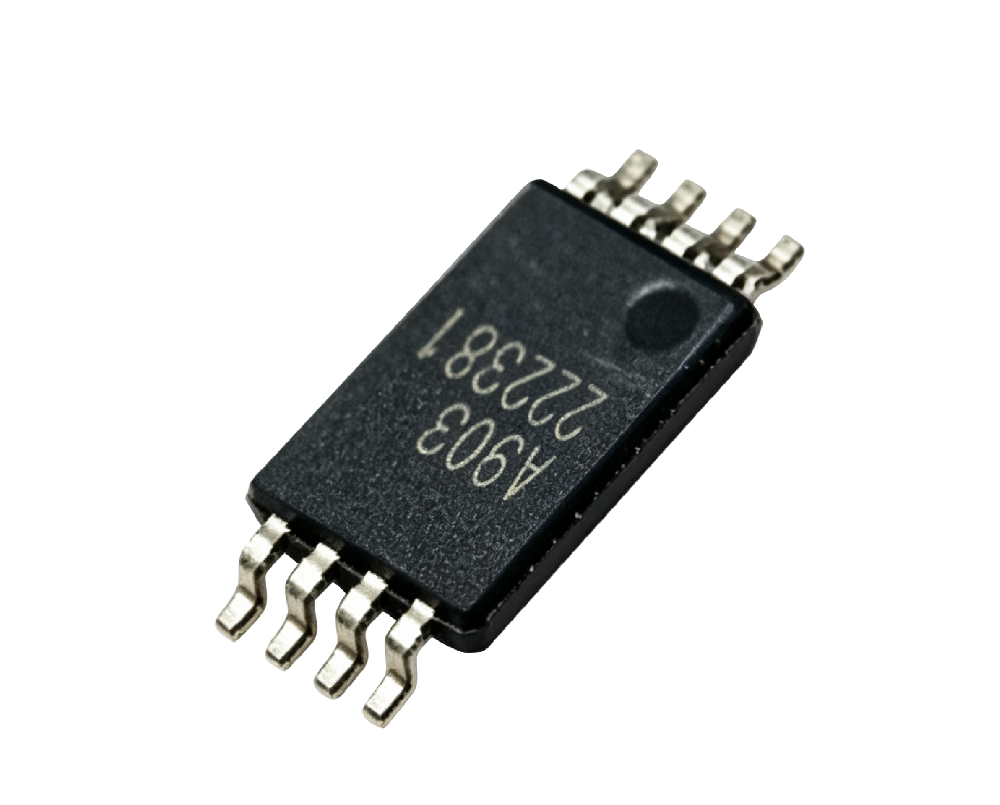
ESSTMAGS offersEAS-081 (optional EAS-081FS functional safety version), encoder kit dedicated to quadruped robot joints, delivered as a set with TMR magnetic sensor IC (BBT-A903) + magnet, suiting robot joints with an outer diameter of 34-48mm;
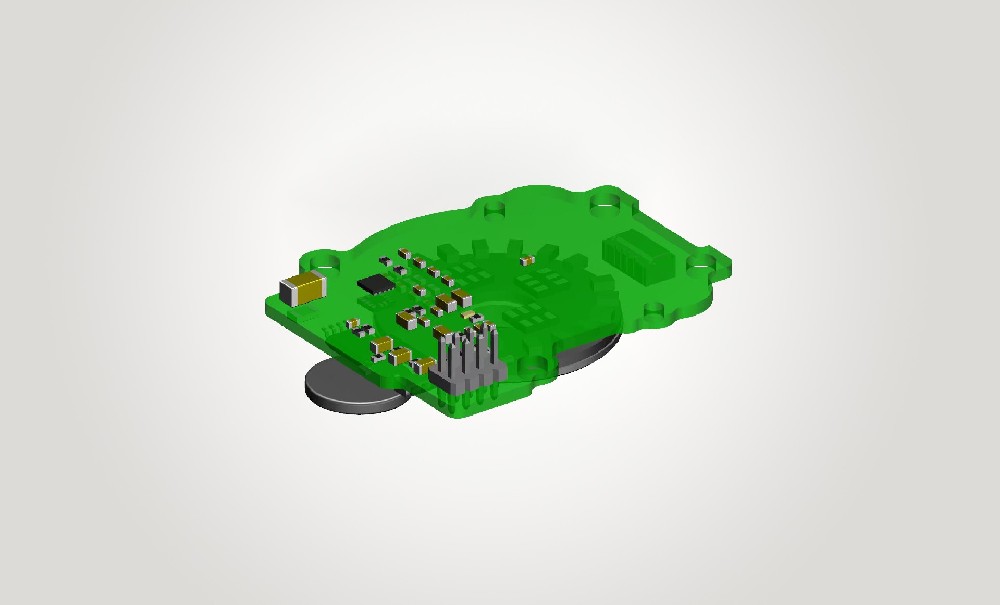
Supports mechanical limited multi-turn detection; the customer only needs to complete PCB integration, with full mounting guidance to shorten R&D cycles.
Core Product Advantages
✅ High shock and vibration resistance: TMR sensing technology, stable angle output under complex dynamic conditions
✅ Compact and easy to integrate: single-IC solution saving precious internal joint space
✅ Excellent detection performance: absolute accuracy <1°, repeatability <0.03°
✅ Extensible solution: supports functional safety version upgrades for high-reliability applications
✅ Domestic IDM, full chain self-controlled: in-house wafer manufacturing, stable supply, supporting scaled cost reduction